ICSE Class 10 Robotics & AI · KIPS Robotics & AI · 35 solved questions
Exercise
1Activity 4.1
Identify the gears:
(a) Gears that are good for moving big things at high speeds.
(b) A gear used to alter the direction of movement between two shafts.
(c) A gear having straight teeth and are placed on shafts that are parallel to each other.
Show SolutionHide Solution↓
(a) Helical gears
(b) Bevel gears
(c) Spur gears
1State True or False
Automatic control systems are faster than manual control system.
Show SolutionHide Solution↓
True
Reason — Automatic control systems respond fast and consistently because they are driven by algorithms and real-time data from sensors, whereas the response time of manual control systems depends on the reaction time and decision-making process of the human operator.
2State True or False
Servo motors are used for heavy industrial tasks.
Show SolutionHide Solution↓
False
Reason — Servo motors are used in robotics, RC (radio-controlled) vehicles, and precision applications where precise and controlled rotation is required, whereas heavy industrial tasks are associated with hydraulic motors, which provide powerful rotating motion.
3State True or False
Hydraulic motor is an example of rotary actuators.
Show SolutionHide Solution↓
True
Reason — Hydraulic motors provide powerful rotating motion and are listed under rotary actuators, which produce rotational motion around an axis.
4State True or False
In fan, ON/OFF system is an example of control system.
Show SolutionHide Solution↓
True
Reason — Fan regulation is an example of a control system. In an on/off control, the fan operates in two states, ON and OFF and the switch controls its functioning, which demonstrates a basic control mechanism.
5State True or False
In refrigerator there is no need of temperature sensor.
Show SolutionHide Solution↓
False
Reason — Refrigerators use a thermostat controller that constantly measures the temperature inside the refrigerator. When the temperature rises above the set limit, the controller activates the compressor to cool the refrigerator, which shows that a temperature sensor is required.
6State True or False
Magnetic sensor is an example of contact sensor.
Show SolutionHide Solution↓
False
Reason — Magnetic sensors detect changes in magnetic fields without making physical contact. Hence, magnetic sensors are non-contact sensors.
7State True or False
Automatic control systems are more adaptable.
Show SolutionHide Solution↓
True
Reason — Automatic control systems may adapt dynamically to changing surroundings, disturbances, or workloads, resulting in robust and adaptable performance, whereas manual control systems depend on the operator’s ability to adjust.
8State True or False
Hybrid control system utilizes more than one controller.
Show SolutionHide Solution↓
True
Reason — Hybrid control combines numerous control systems to handle many elements of the robot’s behaviour at the same time, which means it utilizes more than one control system/controller.
9State True or False
Helical gears have curved teeth.
Show SolutionHide Solution↓
True
Reason — Helical gears have curved teeth, which makes them run more smoothly and quietly compared to spur gears.
10State True or False
Gears do not play any role in robotic mobility.
Show SolutionHide Solution↓
False
Reason — Gears are essential to the gearbox system that powers a robot’s wheels or tracks, enabling the robot to move and traverse different terrains. Hence, gears play an important role in robotic mobility.
1Select the correct option
Which of the following statements best describes a robot?
(a)A device that performs a specific task without adaptability
(b)An advanced machine capable of sensing, decision-making, and interaction
(c)A mechanical tool used for manual tasks
(d)A device that requires constant human supervision
Show SolutionHide Solution↓
An advanced machine capable of sensing, decision-making, and interaction
Reason — A robot is a system that uses sensors to perceive its environment, controllers to process information and make decisions, and actuators to interact with the environment to perform a specific task. This shows that a robot is an advanced machine capable of sensing, decision-making, and interaction.
2Select the correct option
The control system responsible for controlling speed of robot is
(a)Position control system
(b)Velocity control system
(c)Impedance control system
(d)None of these
Show SolutionHide Solution↓
Velocity control system
Reason — Velocity control limits the pace of robot motion, allowing it to travel at a specified velocity along a predetermined course.
3Select the correct option
The task of path planning and trajectory control system is to
(a)Control speed of robot
(b)Decide position of robot
(c)Decide path for robot navigation
(d)Design path for user’s navigation
Show SolutionHide Solution↓
Decide path for robot navigation
Reason — Path planning and trajectory generation involve algorithms in control systems that design the ideal path and produce trajectories for the robot to follow, while avoiding obstacles and taking the robot’s dynamics into account.
4Select the correct option
Servo motor is an example of
(a)Sensor
(b)Actuator
(c)Controller
(d)None of these
Show SolutionHide Solution↓
Actuator
Reason — Servo motors are listed under rotary actuators and are used in robotics and precision applications where precise and controlled rotation is required.
5Select the correct option
Application(s) of pneumatic Cylinder is/are
(a)Pushing
(b)Pulling
(c)lifting items
(d)All of these
Show SolutionHide Solution↓
All of these
Reason — Pneumatic cylinders are used for operations such as pushing, pulling, or lifting items in industrial applications.
6Select the correct option
From following which is an example of non-contact sensor?
(a)Pressure sensor
(b)Gas sensor
(c)Touch sensor
(d)None of these
Show SolutionHide Solution↓
Gas sensor
Reason — Gas sensors detect and measure the concentration of gases in the environment without making physical contact, hence they are non-contact sensors. A pressure sensor is a contact-type sensor as it measures pressure by coming into direct contact with a fluid or gas. A touch sensor is also a contact-type sensor because it detects physical contact or pressure applied to its surface.
7Select the correct option
Camera is an example of
(a)Pressure sensor
(b)Vision sensor
(c)Solar sensor
(d)None of these
Show SolutionHide Solution↓
Vision sensor
Reason — A vision sensor collects visual information from its surroundings, and a camera sensor is listed as an example of a vision sensor used to capture images and videos.
8Select the correct option
Touch sensor is an example of
(a)Tactile sensor
(b)Vision sensor
(c)Pressure sensor
(d)None of these
Show SolutionHide Solution↓
Tactile sensor
Reason — Tactile sensors collect data from physical interactions with the environment, and touch sensors are listed as examples of tactile sensors, as they detect physical contact or pressure applied to their surface.
9Select the correct option
Electric solenoids, are mainly utilised in?
(a)Locking mechanisms
(b)Doorbells
(c)Automatic door openers
(d)All of the above
Show SolutionHide Solution↓
All of the above
Reason — Electric solenoids are used in a variety of applications such as locking mechanisms, doorbells, and automatic door openers.
10Select the correct option
From following which is/are the component(s) of robot?
(a)Controller
(b)Sensor
(c)Actuator
(d)All of the above
Show SolutionHide Solution↓
All of the above
Reason — The important components of a robot include the sensor, actuator, controller.
1Fill blanks
Fill in the blanks:
(a)Sensors transform physical parameters into ................ .
(b)................ combines numerous control systems to handle many elements of the robots.
(c)................ is commonly used in modern air conditioners to vary the compressor's speed.
(d)Impedance control allows the robot to respond to ................ .
(e)Task of ................ is to understand input signals and generate control signals.
Show SolutionHide Solution↓
Sensors transform physical parameters into electrical signals.
Hybrid control system combines numerous control systems to handle many elements of the robots.
Inverter technology is commonly used in modern air conditioners to vary the compressor's speed.
Impedance control allows the robot to respond to external pressures.
Task of controller is to understand input signals and generate control signals.
1Short answer type questions
How does the feedback system work in robots? Explain.
Show SolutionHide Solution↓
The feedback system in robots works by sending information about the robot’s current output or action back to the controller. This feedback indicates parameters such as the robot’s location, orientation, or movement. Based on this feedback, the controller fine-tunes its control signals to correct errors and ensure that the robot performs the desired task accurately. If the robot does not perform the intended action, negative feedback is sent to the controller, which then adjusts its functioning accordingly.
2Short answer type questions
Explain the range and proximity sensor.
Show SolutionHide Solution↓
Proximity sensors are non-contact sensors that detect the presence of an object when it enters the sensor’s field. The sensor may use sound, light, infrared, or electromagnetic fields to detect the object. A range sensor determines the distance between the sensor and the object in its proximity. Examples include ultrasonic sensors, which are used in object detection and measuring distance, and proximity sensors, which are used in cell phones and home appliances.
3Short answer type questions
Explain any one robotic control system.
Show SolutionHide Solution↓
Position control system ensures that the robot’s joints or end-effectors move properly to specific locations. In this control system, the robot’s position is measured and compared to the desired position, and based on this comparison, control signals are generated to achieve accurate movement.
4Short answer type questions
By which method can a robot accept input? Explain.
Show SolutionHide Solution↓
A robot can accept input through sensors or from a human operator. In fully autonomous systems, the input is provided by sensors, while in some systems, inputs can also be given by human operators to control the robot’s actions.
5Short answer type questions
What do you understand by gear ratio? Explain.
Show SolutionHide Solution↓
Gear ratio shows how the number of teeth on the driving gear (input) relates to the number of teeth on the driven gear (output).
Gear Ratio = Number of driven gear teeth / Number of driving gear teeth
It shows the number of times the output gear turns in relation to the input gear. In a mechanical system, the speed and power depend on the gear ratio.
If the driven gear has more teeth, it rotates slower but with greater power.
If the driven gear has fewer teeth, it rotates faster but with less power.
1Long answer type questions
What are the various applications of gear in robotics?
Show SolutionHide Solution↓
Gears play an important role in robotic systems and are used for various applications. The applications of gears in robotics are as follows:
Robotic joints: Gears are used in robotic joints to allow smooth and accurate movement. Depending on the required motion range and torque capability, different types of gears such as spur gears and harmonic drive gears are used.
Robotic mobility: Gears are essential to the gearbox system that powers a robot’s wheels or tracks, enabling the robot to move quickly and traverse a variety of terrains.
Lifting mechanisms: Gears are used to magnify force, which allows robots to carry heavy loads. This application is commonly seen in material handling and lifting robots.
Accuracy and control: Robotic systems that require precise control and positioning, such as those used in robotic surgery and industrial automation, frequently use worm gears.
Gearboxes: Gearboxes are used to adjust the torque and speed of robotic actuators according to specific tasks or movements, ensuring efficient robot performance.
2Long answer type questions
Write about various applications of hydraulic motors.
Show SolutionHide Solution↓
Hydraulic motors offer powerful rotating motion and are used in the following applications:
Heavy equipment
Construction machines
Automobiles
3Long answer type questions
Write about various applications of actuators.
Show SolutionHide Solution↓
The various applications of actuators are as follows:
In robotic arms and joints to control the movement and orientation of different joints and links.
To automate manufacturing tasks in conveyor systems, valves, and process control.
To regulate the flight of aircraft control surfaces such as ailerons and flaps.
In automotive components such as power windows, door locks, and engine control.
In ventilation and air conditioning systems to regulate airflow and temperature.
4Long answer type questions
Write the difference between manual and automatic control systems.
Show SolutionHide Solution↓
The differences between manual control systems and automatic control systems are as follows:
Characteristic
Manual Control System
Automatic Control System
Working
A human operator directly manipulates the robot’s actions and motions in manual control of robotics. To direct the robot’s movements, the operator uses input devices such as joysticks, control panels, or teaching pendants.
Robots work automatically based on control algorithms and feedback systems. Sensors on the robot measure its location, orientation, and other inputs. The control system generates control signals based on the data provided by sensors. The signals are sent to the robot’s actuators to achieve the desired task.
Mechanism of control
The human operator’s actions and orders have a direct impact on the robot’s actions.
The robot’s actions are driven by control algorithms and feedback.
Response time
The response time is determined by the reaction time and decision-making process of the human operator. It varies based on the operator’s experience and competence.
Because they are driven by algorithms and real-time data from sensors, automatic control systems can respond fast and consistently.
Precision
Because it relies on the operator’s motor abilities and judgement, manual control may lack precision and fine-grained accuracy.
Due to constant feedback and computing capabilities, automatic control may achieve great precision and accuracy.
Complexity
Manual control is easier and more straightforward, making it appropriate for basic robot operations or activities that do not need complicated tasks.
Automatic control can deal with complicated robot tasks.
Adaptability
Because it relies on the operator’s capacity to adjust, manual control may have difficulties in adjusting quickly to changing circumstances or complex jobs.
Automatic control systems may adapt dynamically to changing surroundings, disturbances, or workloads, resulting in robust and adaptable performance.
5Long answer type questions
Make a block diagram of the robot and explain it.
Show SolutionHide Solution↓
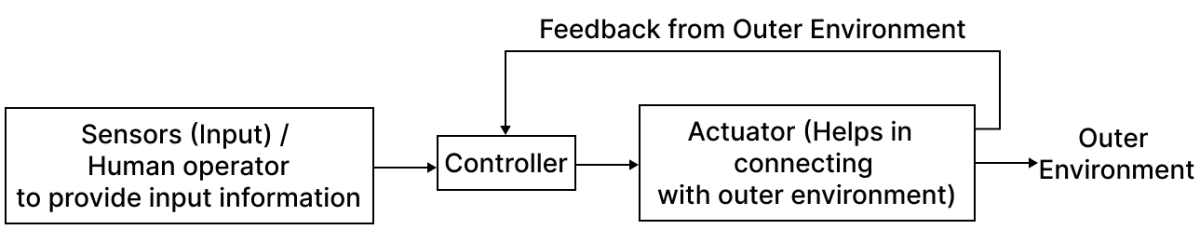
The block diagram of a robot is shown below. It is showing the flow of information between the input and output.
Each component of the above block diagram is explained below.
Input: This block consists of sensors in fully autonomous systems. The inputs can be provided by human operators as well.
Controller: Task of controller is to understand input signals and generate control signals. Control signals also depend on feedback which is received from output generated by robot.
Feedback: The feedback is sent from the output end of the robot. It indicates the robot's current output or action which may be its location, orientation, or any other task. It helps the controller fine-tune its control signals and perform the desired task more accurately. For example, if a robot does not perform the desired task or make the desired move, negative feedback will be sent to the controller, and controller will change its functioning accordingly.
Actuator: This component is driven by the control signal generated by the controller. These are the devices that help robots connect with outside world.
1Higher Order Thinking Skills (HOTS)
What could be the challenges with a fully automatic control system?
Show SolutionHide Solution↓
A fully automatic control system can face several challenges. Since it works based on control algorithms and feedback from sensors, its performance depends completely on the accuracy of sensors and control algorithms. Any error in sensor data or malfunction of components can affect the system’s operation. Automatic control systems are also more complex, as they are designed to handle complicated robot tasks, which makes their design, programming, and maintenance more difficult. In addition, such systems require constant feedback and computing capability to function correctly.
2Higher Order Thinking Skills (HOTS)
What would happen if there was no concept of gears?
Show SolutionHide Solution↓
If there were no concept of gears, robots would not be able to transmit motion and power effectively from one component to another. The amplification of force and adjustment of speed and torque would not be possible, which would affect robotic joints, mobility, and lifting mechanisms. Robots would face difficulty in achieving smooth, accurate movement, precise control, and the ability to carry heavy loads. Applications such as robotic mobility, lifting mechanisms, and accurate positioning would be severely limited without gears.
3Higher Order Thinking Skills (HOTS)
What components would be required in an obstacle avoiding wheeled robot?
Show SolutionHide Solution↓
An obstacle avoiding wheeled robot would require the following components: